27.10.2026 by Viktor Siebert
Yaskawa SGMGH-13DCA-YG11: Alarm A.84 and encoder repair
Yaskawa SGMGH-13DCA-YG11: alarm A.84 following emulsion ingress
This Yaskawa AC servo motor arrived at industrypart with alarm A.84. Inspection revealed emulsion ingress through a seal. The resulting contamination had reached the encoder compartment, affecting the ball bearings and the encoder code disk. We completely overhauled the motor, renewed the code disk and subsequently carried out programming, adjustment and testing.
Understanding alarm A.84
The incoming description referred to A.84 as a disconnected encoder. However, the Yaskawa reference identifies A.84 as an encoder data error. An alarm is initially a monitoring indication, not conclusive evidence of a broken cable. In this repair case, inspection identified damage within the motor and encoder area.
The Sigma II manual uses the term “Absolute Encoder Data Error”. The supplementary Yaskawa FAQ MNEN-5CJMKE explicitly discusses A.84 for both absolute and incremental encoders. The supplied encoder is marked “INCR. ENCODER UTSIH-B17CK” and is therefore described here as an incremental encoder.
Technical data of the documented motor
| Manufacturer / model | Yaskawa SGMGH-13DCA-YG11 |
| Device type | AC Servo Motor |
| Rated output | 1,300 W / 1.3 kW |
| Rated torque | 8.34 N·m |
| Rated speed | 1,500 rpm |
| Rated voltage / current | 400 V / 8.3 A |
| Duty / insulation class | CONT. / F |
| O/N | 6G0073 034 -009 |
| S/N | B0065F076410009 |
| DATE | 0605 |
| Encoder marking | UTSIH-B17CK, INCR. ENCODER |
| Amplifier used for workshop testing | Yaskawa SGDH-10DE-OY |
The electrical and mechanical ratings come from the supplied nameplate. Rated speed does not specify the maximum permissible speed. Insulation class F is a thermal classification, not a current insulation measurement. The test amplifier designation follows the workshop information.
How the motor, feedback and amplifier work together
The servo amplifier supplies controlled electrical power to the motor, which converts it into shaft torque. Feedback provides the motion information used by the control system. Power and signal paths must therefore be considered separately: an intact winding alone does not ensure reliable motion when feedback is impaired.
The mechanical assembly includes the shaft, rotor and bearings. Sealing points limit liquid and dirt ingress. The encoder detects rotation, with the code disk forming part of that sensing arrangement. Damage or contamination in this area can impair reliable feedback. Mechanical repair and subsequent encoder alignment therefore belong together.
Replacement parts must match the complete SGMGH-13DCA-YG11 variant. Equal power and apparently matching connectors do not establish interchangeability. Flange, shaft, electrical data, feedback, pin assignment and machine settings must agree. Testing with the SGDH-10DE-OY documents the workshop pairing used; it does not establish approval for other machine configurations.
Findings and repair work
| Area | Finding and action |
| Seals | Emulsion ingress through a seal identified; seals replaced. |
| Ball bearings | Damage associated with liquid and dirt ingress; ball bearings replaced. |
| UTSIH-B17CK encoder | Code disk renewed; renewed encoder programmed for the motor and adjusted. |
| Housing and surfaces | Thoroughly cleaned, old paint removed and special industrial paint applied. |
| Complete unit | Preventively overhauled and subsequently tested with Yaskawa SGDH-10DE-OY. |
Renewing the code disk addresses the documented sensing damage. Programming and adjustment match the feedback to the individual motor. Repainting improves surface condition but does not replace sound seals or protection of the connections from emulsion.
What to distinguish during fault diagnosis
When diagnosing a feedback fault, distinguish the encoder, connectors, cable and amplifier as possible fault locations. Visible liquid traces help track an ingress route, but do not replace functional testing. An alarm alone likewise does not prove total encoder failure.
The investigation should also consider bearing condition and possible vibration sources. The Yaskawa FAQ lists interference and excessive mechanical vibration among possible factors for A.84. In this case, however, liquid and dirt ingress was specifically identified. That confirmed finding must be distinguished from general diagnostic possibilities.
Selected alarm reference for Sigma II SGDH
Only A.84 was reported in this case. The other entries help distinguish fault categories using the cited family manual. Application requires consideration of the specific software and machine variant.
| A.10 | Overcurrent or heatsink overheating |
| A.51 | Overspeed |
| A.71 / A.72 | Overload |
| A.84 | Encoder data error, see explanation above |
| A.C9 | Encoder communication error |
| A.CA | Encoder parameter error |
| A.Cb | Encoder reply error |
| A.d0 | Excessive position error |
Test run and prevention
Following overhaul, the motor was tested with the Yaskawa SGDH-10DE-OY. The video shows an excerpt from the actual test run. A specific load profile, test duration and numerical measurements were not supplied for this report.
Maintenance should include regular checks of seals, connector areas and cable routes for moisture and deposits. Recurring emulsion ingress should be addressed at its source. New seals alone cannot compensate for continuously adverse installation conditions. Unusual noise or changes in running behaviour should be investigated promptly.
Sources and scope
Case information: customer description, workshop findings, nameplate, encoder photograph and original test video. Manufacturer references: Yaskawa Sigma II Servo System User’s Manual, YEA-SIA-S800-32.2, Rev. K-1, section 9.2, particularly page 9-22 and alarm table pages 9-40 and 9-41; supplemented by Yaskawa FAQ MNEN-5CJMKE (30.06.2008).
Test video after overhaul
Before and after repair photographs
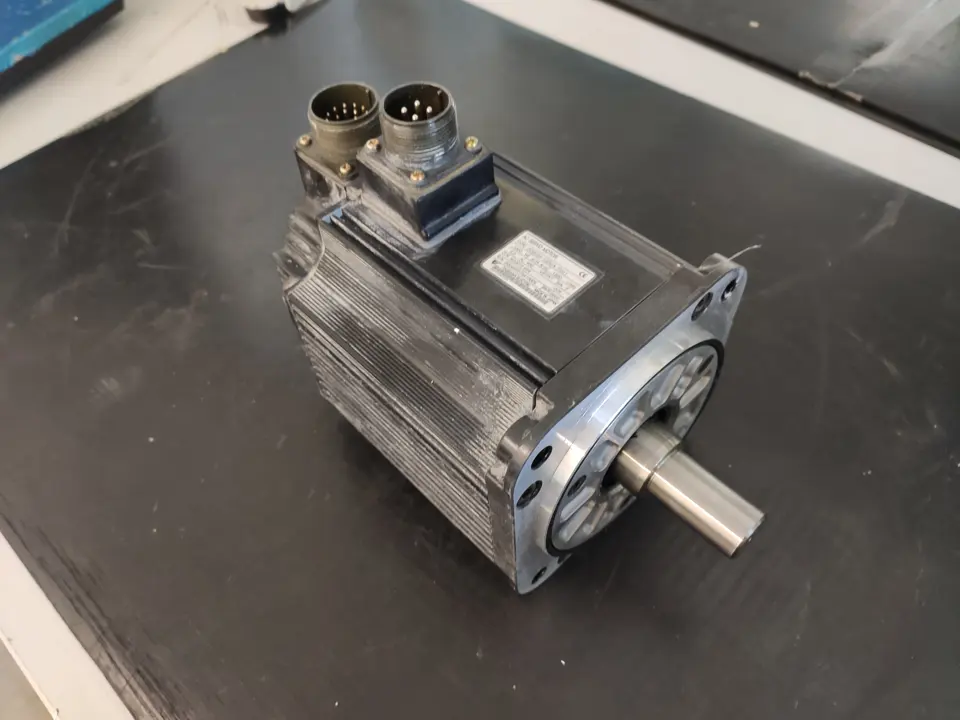 Before repair: shaft and housing | Yaskawa SGMGH-13DCA-YG11
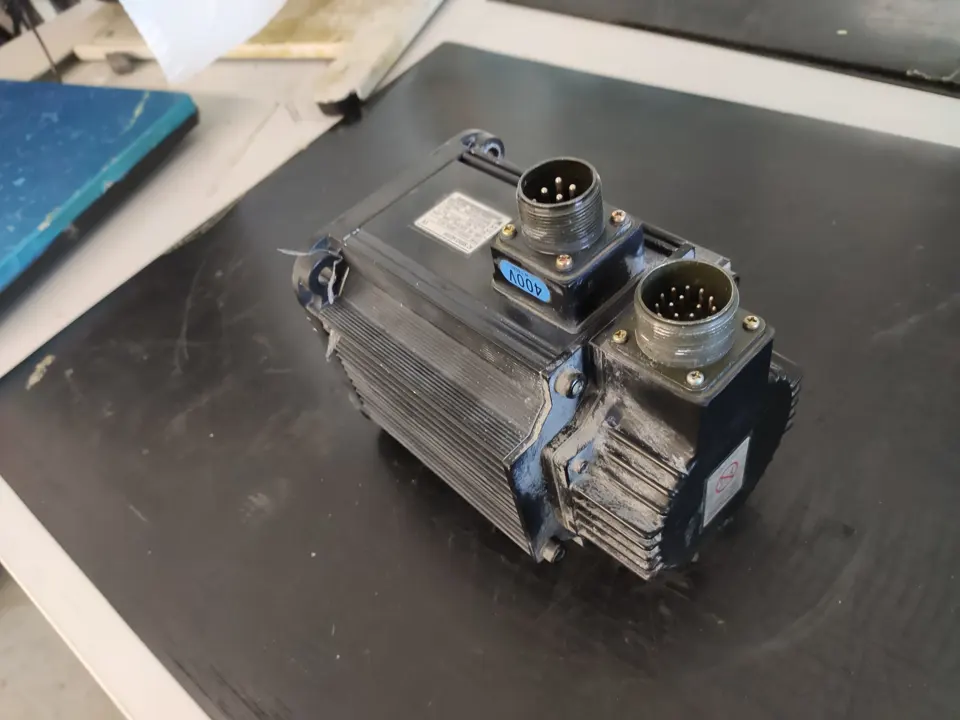 Before repair: encoder side | Yaskawa SGMGH-13DCA-YG11
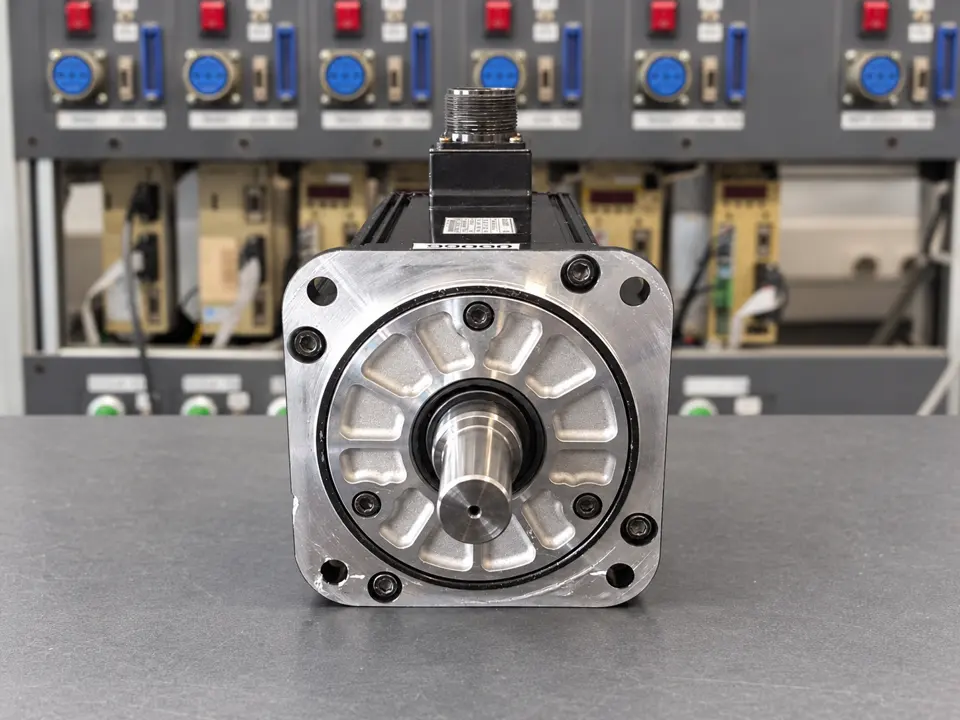 After repair: front view | Yaskawa SGMGH-13DCA-YG11
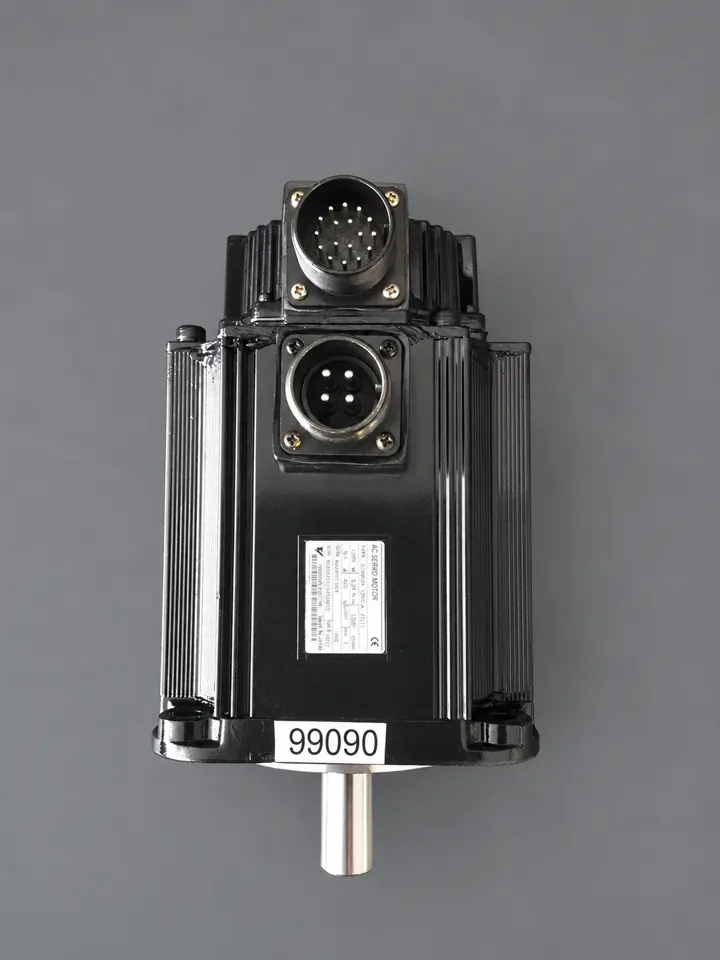 After repair: connections | Yaskawa SGMGH-13DCA-YG11
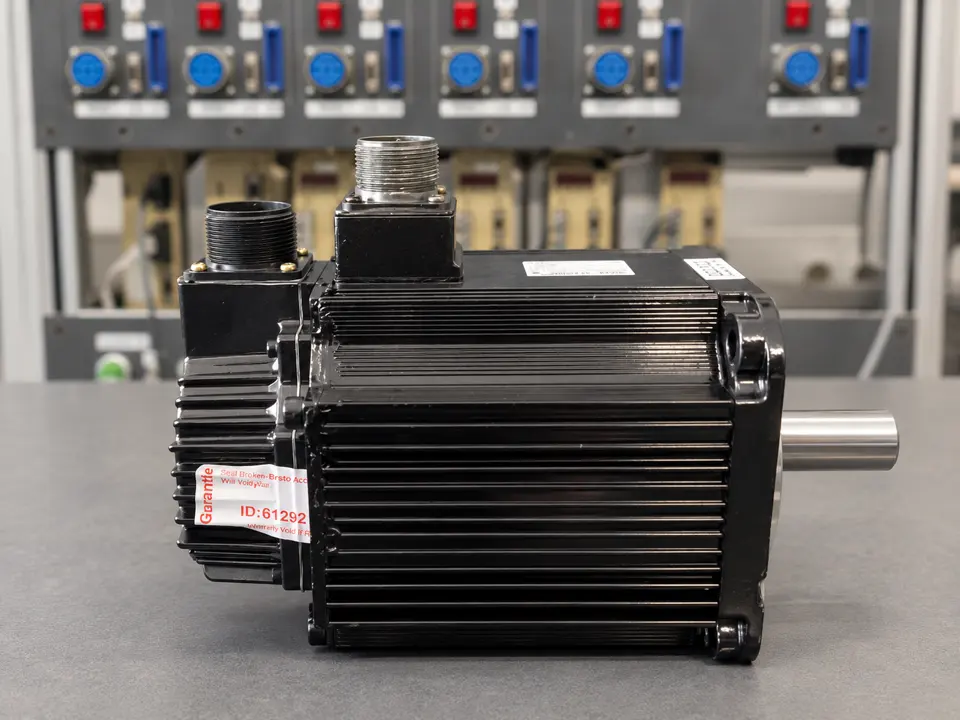 After repair: side view | Yaskawa SGMGH-13DCA-YG11
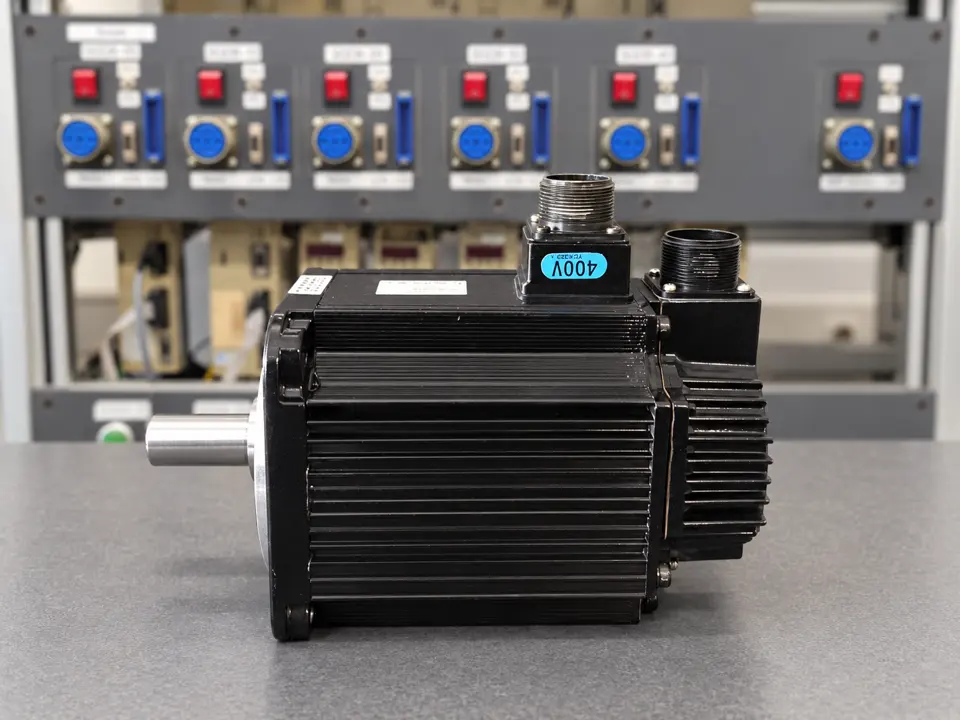 After repair: opposite side | Yaskawa SGMGH-13DCA-YG11
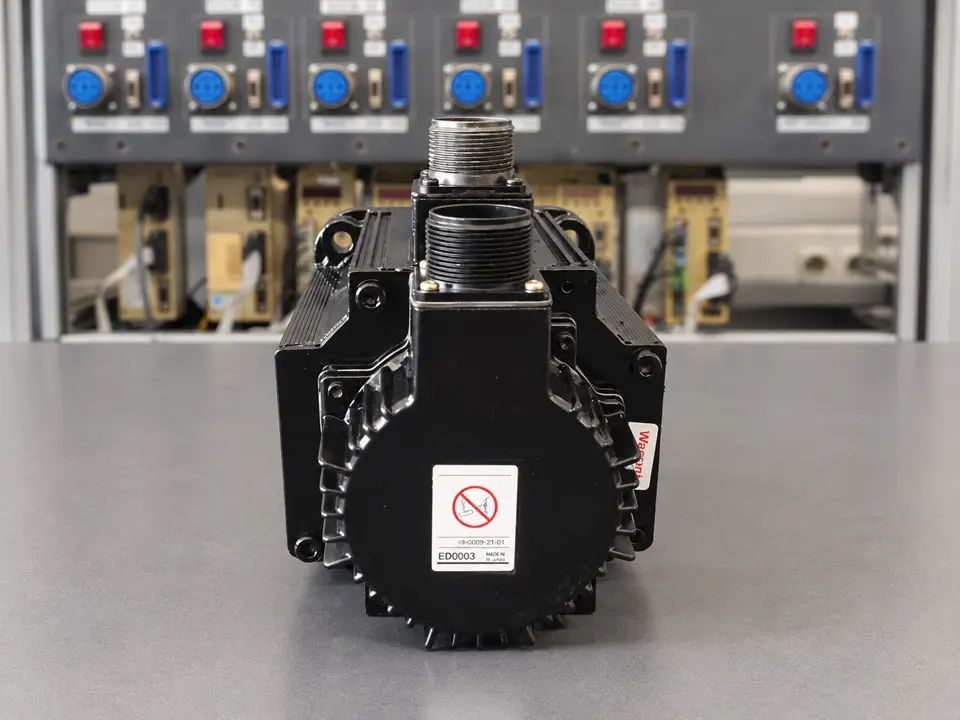 After repair: encoder housing | Yaskawa SGMGH-13DCA-YG11
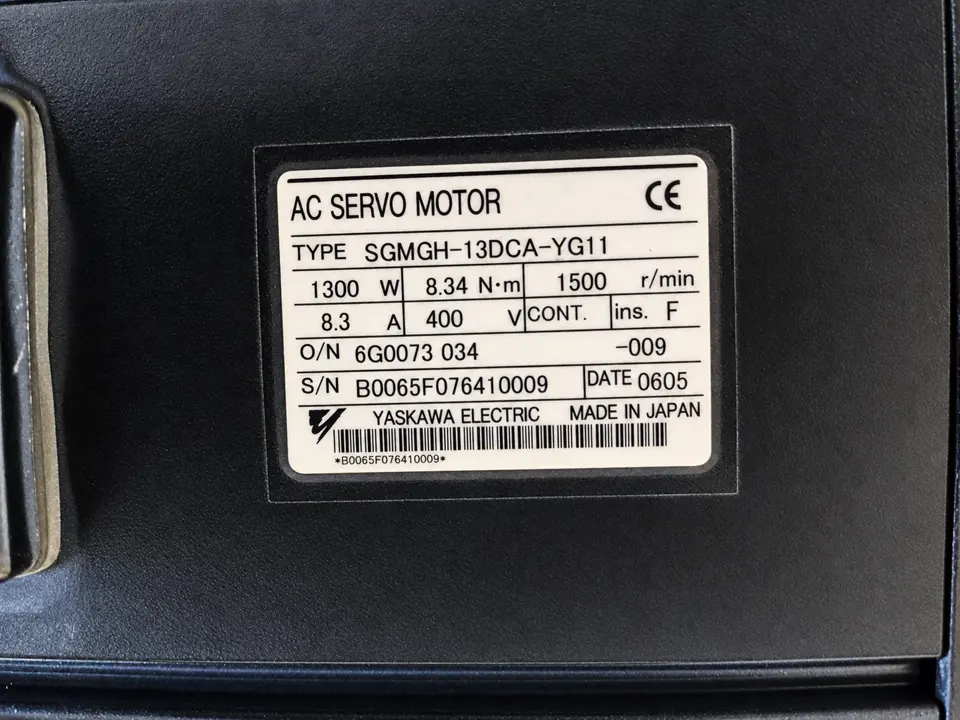 Nameplate | Yaskawa SGMGH-13DCA-YG11
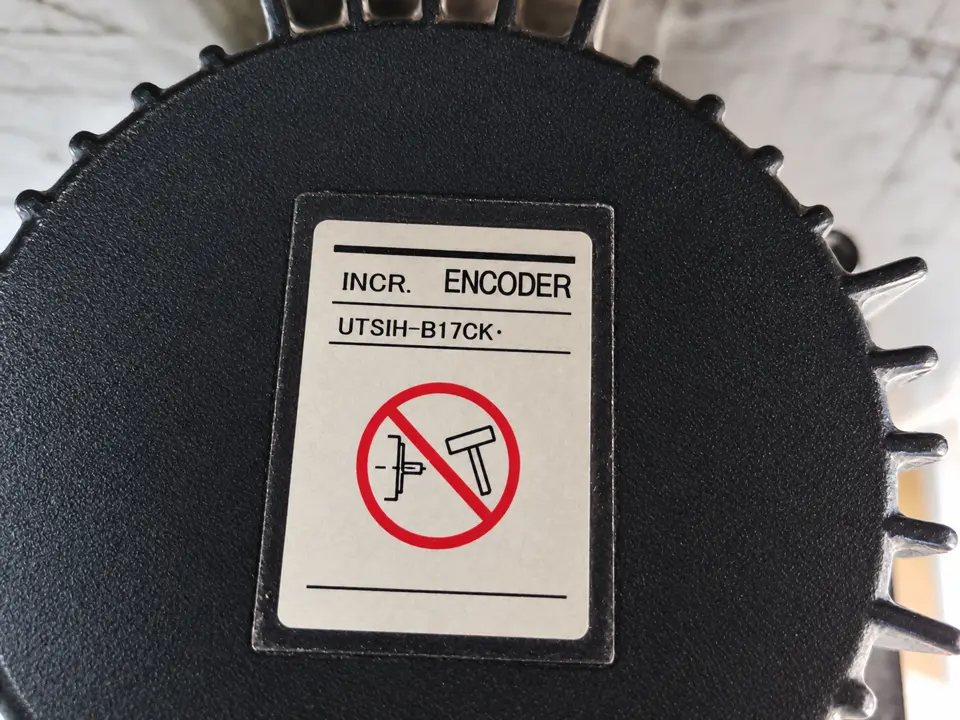 UTSIH-B17CK encoder | Yaskawa SGMGH-13DCA-YG11
Request a repair assessment
Send the complete motor designation, nameplate, amplifier type and observed alarm. Details of liquid exposure and operating conditions support diagnosis. industrypart provides repair and preventive overhaul of industrial servo motors.
Yaskawa SGMGH-13DCA-YG11 AC Servo Motor
For more information, visit our Yaskawa repair service.