18.09.2026 by Viktor Siebert
Yaskawa SGM-08V3B4 Servo Motor: Positioning Error Caused by a Defective TRD-Y2048 Encoder
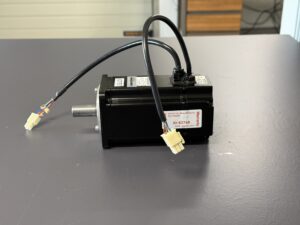
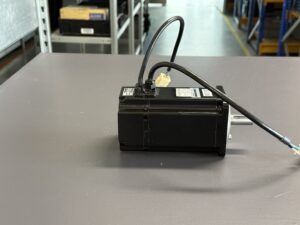
The Yaskawa AC servo motor SGM-08V3B4 was sent to industrypart for inspection and repair. The motor was installed in a rotary indexing unit used to position workpieces or components precisely at predefined angles.
According to the customer, the required 90-degree positions could no longer be reached accurately. The indexing unit repeatedly stopped outside the specified target position. The customer therefore suspected that the encoder installed in the motor was no longer detecting the movement correctly or was failing to count individual pulses reliably.
In this application, the Yaskawa SGM-08V3B4 operates together with a Yaskawa SGDB-10ADG servo drive. A Yaskawa TRD-Y2048 encoder is used as the feedback system.
Fault Description in the Machine
The fault reported by the customer was not a complete motor failure. The servo motor could still move, but the specified angular position was no longer reached accurately.
Precise positioning is essential in a rotary indexing unit. If a 90-degree movement is specified, for example, the servo drive must use the encoder feedback to determine:
- the current position of the motor shaft,
- the direction in which it is moving,
- the speed of the movement,
- and the point at which the specified target position has been reached.
If encoder pulses are incorrect, incomplete or transmitted inconsistently, a discrepancy develops between the actual position and the position detected by the drive. As a result, the indexing unit may fail to reach its target position precisely, or the deviation may increase after several positioning cycles.
Function of the Yaskawa TRD-Y2048 Encoder
The TRD-Y2048 is the feedback system of the servo motor. It detects the rotation and position of the motor shaft and supplies the corresponding feedback signals to the Yaskawa SGDB-10ADG.
The servo drive continuously compares the specified target position with the actual position reported by the encoder. The servo control uses this deviation to calculate the motor movement required.
A defective encoder signal does not necessarily result immediately in a clear alarm message. Depending on the type of defect, intermittent or gradually developing faults are also possible. These may include inaccurate positioning, incorrect angular movements, unstable motor operation or positioning deviations that become apparent only after several movement cycles.
In this case, the customer did not report a specific alarm code. The decisive symptom was the rotary indexing unit’s inability to reproduce the required 90-degree positions accurately.
Incoming Inspection and Diagnosis
After arrival, the Yaskawa SGM-08V3B4 was first identified using the nameplate and the available connection and encoder information.
The nameplate shows the following values:
- Rated power: 750 W
- Rated voltage: 200 V
- Rated current: 4.4 A
- Rated torque: 2.39 Nm
- Rated speed: 3,000 rpm
- Insulation class: B
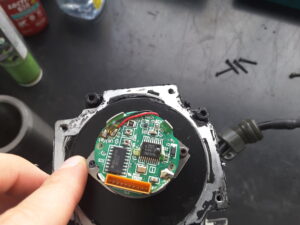
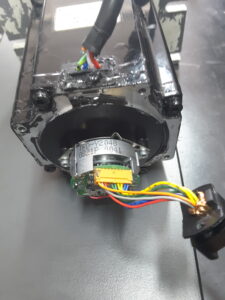
During diagnosis, the encoder was identified as the cause of the positioning fault. The installed Yaskawa TRD-Y2048 was no longer providing sufficiently reliable feedback for precise position control.
With this type of fault, the associated cables, connectors and signal transmission to the servo drive must generally also be inspected. Mechanical play in the rotary indexing unit, coupling or gearbox must also be considered because it can cause similar positioning deviations.
In this repair case, however, the fault was traced to the motor’s encoder system.
Replacement of the Defective Encoder
The defective Yaskawa TRD-Y2048 encoder was replaced. Replacing a motor encoder involves more than simply installing a mechanically compatible feedback device.
The encoder must be compatible with the specific motor version and the servo drive being used. Correct mechanical installation, alignment, signal sequence and a secure connection to the motor shaft are also essential. Even minor deviations can cause unstable motor operation, an incorrect feedback direction or renewed positioning problems.
After installation, the encoder was therefore not tested in isolation. It was tested together with the servo motor and the original Yaskawa SGDB-10ADG servo drive.
Replacement of Bearings and Seals
As part of the repair, the motor bearings and seals were also replaced. These operations are included in the overhaul of a servo motor at industrypart.
Worn bearings can cause mechanical play, running noise, vibration and irregular rotation. In applications requiring high positioning accuracy, these mechanical factors can also affect the precision of the axis.
The seals protect the inside of the motor and the encoder system against dirt, oil, coolant and other external influences. Damaged or aged seals increase the risk of contaminants entering the motor or encoder area.
Replacing the encoder, bearings and seals therefore not only eliminated the diagnosed electronic fault but also provided a mechanical overhaul of the motor.
Functional and Positioning Test with the Original Servo Drive
After completion of the repair, the Yaskawa SGM-08V3B4 was tested with an original Yaskawa SGDB-10ADG servo drive.
This combination is particularly important for a meaningful final test. The servo drive supplies the motor, processes the encoder pulses and controls speed, direction and position. This allows the interaction between the motor, encoder and drive electronics to be checked under realistic conditions.
During testing, the motor operation and the feedback from the new encoder were checked. Particular attention was paid to the positioning function because this was the source of the customer’s original complaint.
After the repair, the motor was once again able to approach the specified positions correctly. Positioning with the new TRD-Y2048 encoder operated reliably in combination with the original SGDB-10ADG. The original fault could no longer be reproduced during final testing.
Why Testing the Motor Without the Correct Servo Drive Is Insufficient
Resistance and insulation measurements can provide important information about the condition of the motor windings. However, they do not confirm that the complete servo control and position feedback system are operating correctly.
Dynamic testing is particularly important in cases involving encoder faults. Only during operation can it be determined whether:
- all encoder signals are transmitted correctly,
- the signal sequence corresponds to the direction of rotation,
- the servo drive detects the motor position correctly,
- the motor runs smoothly,
- and the specified positions are reached repeatedly.
For this reason, the SGM-08V3B4 was tested together with the intended Yaskawa servo drive rather than only as an individual motor.
Preventive Recommendations for Rotary Indexing Units and Positioning Axes
Emerging positioning problems should not be ignored until a clear alarm message appears. Incorrect positioning can result in rejected parts, tool damage or machine collisions.
For comparable applications, the following points should be inspected regularly:
- Condition of the encoder cable and connectors
- Correct grounding and shielding of the signal cables
- Mechanical play in the coupling, gearbox and rotary indexing unit
- Unusual bearing noise or vibration
- Contamination caused by oil, dust or coolant
- Complete alarm display on the servo drive
- Development of the position deviation over several movement cycles
Before replacing a motor or encoder, the complete motor designation, encoder designation and servo drive model should also be documented. Different versions may look similar externally but may not be electrically compatible or suitable for the same feedback system.
Conclusion
The inaccurate 90-degree positioning of the rotary indexing unit was caused by a defective Yaskawa TRD-Y2048 encoder installed on the SGM-08V3B4 servo motor.
During the repair, the defective encoder was replaced. The motor bearings and seals were also renewed. The motor was then tested using the original Yaskawa SGDB-10ADG servo drive.
During final testing, the positioning function operated correctly again. This repair case demonstrates that encoder problems do not always result immediately in complete motor failure or a clear alarm message. Gradually developing deviations in repeated angular positions can also indicate a defective feedback system.
Price, Lead Time and Further Information
No clearly corresponding product page for the Yaskawa SGM-08V3B4 could currently be found on the website. Therefore, no unverified product URL is provided.
Further information about our repair services for Yaskawa servo motors is available in our Yaskawa service section.
Further information about the repair and replacement of Yaskawa encoders for servo and spindle motors can be found on our encoder service page. The TRD-Y2048 is also listed there as an encoder model supported by industrypart.
📞 Please feel free to contact us if you have any questions about your Yaskawa motor technology, a positioning fault or a specific repair case. Our experienced team will be pleased to assist you with the technical assessment, repair and testing of your motor.
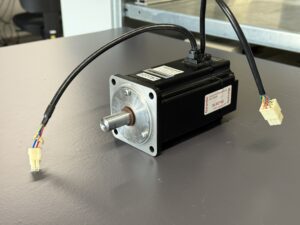
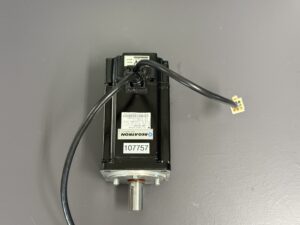
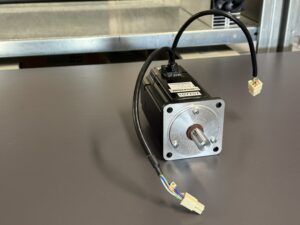
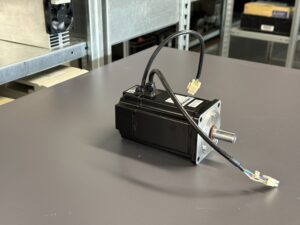
Information about the mentioned Servopack and Servomotor:
More information about our Yaskawa repairs can be found here.
📞 Feel free to contact us if you have any questions regarding your Yaskawa drive technology. Our experienced team is always ready to assist you.
Technical Specifications
| Feature | Technical information |
|---|
| Manufacturer | Yaskawa Electric Corporation |
| Model | SGM-08V3B4 |
| Alternative designation | Yaskawa AC Servo Motor SGM-08V3B4 |
| Order number according to nameplate | 4B1622-1-2 |
| Device type | AC servo motor |
| Rated power | 750 W |
| Rated voltage | 200 V |
| Rated current | 4.4 A |
| Rated torque | 2.39 Nm |
| Rated speed | 3,000 rpm |
| Insulation class | B |
| Encoder | Yaskawa TRD-Y2048 |
| Servo drive used | Yaskawa SGDB-10ADG |
| Customer application | Positioning a rotary indexing unit in 90-degree increments |
| Manual reference | SGDB alarm table provided by the customer, “Error Displays With Digital Operator and Traceback Data” |
Application Environment and Compatible Devices
In this case, the SGM-08V3B4 was operated together with a Yaskawa SGDB-10ADG. The motor was part of a positioning axis in a rotary indexing unit.
Before replacing a servo motor, encoder or servo drive, the complete model designations and the motor, feedback and connection versions must be checked. A mechanically compatible component is not automatically electrically or functionally compatible with the control system.
Existing parameters, the machine configuration and the encoder connector pin assignment must also be considered.
Functional Description
The servo drive supplies the controlled electrical power to the motor. Depending on the higher-level machine controller, the drive receives a command value for movement, speed or position.
The TRD-Y2048 detects the movement of the motor shaft and supplies feedback signals to the SGDB-10ADG. The drive continuously compares the feedback signal with the command value and corrects deviations by adjusting the motor control.
If an error occurs in the encoder signal, the control system loses some of the reliable information about the actual movement. The consequences can range from intermittent positioning deviations to an encoder or feedback alarm.
Components
The following overview contains only the main components clearly documented in this repair case.
| Assembly | Designation | Quantity | Function | Inspection or repair information |
|---|
| Servo motor | Yaskawa SGM-08V3B4 | 1 | Generates the controlled rotary movement | Check windings, insulation, concentricity and motor operation |
| Encoder | Yaskawa TRD-Y2048 | 1 | Detects motor-shaft movement and position | Defective and replaced in this repair case |
| Servo drive | Yaskawa SGDB-10ADG | 1 | Supplies, controls and regulates the motor | Used for final functional and positioning tests |
| Rotary indexing unit | Customer application | 1 | Positions the machining axis at defined angular increments | Check mechanical play in comparable fault cases |
Alarm Messages and Troubleshooting
The customer did not report a specific alarm code in this repair case. The following table is based on the provided SGDB fault overview and lists relevant encoder, feedback and drive faults. Not all listed alarms apply to every motor and encoder configuration.
| Code | Original designation | Technical meaning | Possible cause | Inspection or measure |
|---|
| A.00 | Absolute Encoder Data Error | Error in the absolute encoder data | Invalid or defective encoder data | Relevant only when an absolute encoder is used |
| A.01 | Absolute Encoder Data Error | Error in the absolute encoder data | Data transmission or encoder fault | According to the table, only applicable to SGDB systems with an absolute encoder |
| A.40 | Overvoltage | Excessive voltage | Excessive DC-bus voltage or regenerative energy | Check the power supply and braking or regeneration conditions |
| A.51 | Feedback Overspeed | Excessive speed detected by the feedback system | Feedback signal exceeds 110% of the maximum speed | Check the encoder, signal transmission and actual speed |
| A.70 | Overload | Overload condition | Excessive mechanical or electrical load | Check the load, motor operation and mechanical system |
| A.71 | Overload | Momentary overload | Brief excessive motor load | Check the axis for stiffness and excessive load |
| A.72 | Overload | Continuous overload | Prolonged excessive load | Check the load profile, mechanical system and motor condition |
| A.C1 | Overrun | Overrun or impermissible movement | Control deviation or movement error | Check the command value, feedback and mechanical system |
| A.C2 | Encoder Phase Detection Fault | Fault in encoder phase detection | Defective phase or encoder signal | According to the table, relevant when an incremental encoder is used |
| A.C3 | PA-, PG-Phase Disconnection of PG Signal Line | Interruption of the PA/PG signal line | Cable, connector or encoder fault | Check the encoder cable and connections |
| A.C4 | PC Disconnection | Interruption of the PC signal | Cable interruption or encoder fault | Check the PC signal and connectors |
| A.F1 | Power Supply Line Open Phase | Open phase in the power supply | Interrupted or missing supply phase | According to the table, relevant to SGDB |
| A.F3 | Momentary Power Loss Error | Brief power-supply interruption | Voltage dip or interruption of the power supply | Check the mains supply and connections |
Diagnostic Information for the Main Fault
| Inspection point | Finding or meaning |
|---|
| Customer complaint | The rotary indexing unit no longer reached the specified 90-degree position accurately |
| Alarm display | No specific alarm code reported by the customer |
| Identified cause | Defective Yaskawa TRD-Y2048 encoder |
| Possible external causes in similar cases | Encoder cable, connectors, shielding, coupling, gearbox or mechanical play |
| Possible internal causes | Encoder fault, defective signal transmission, worn bearings or contamination |
| Repair performed | Encoder replaced; bearings and seals renewed |
| Final test | Tested using the original Yaskawa SGDB-10ADG |
| Result | Positioning operated correctly after the repair |
Preventive Measures
- Do not route encoder cables together with power cables that generate strong electrical interference.
- Check connectors regularly for secure seating, contamination and corrosion.
- Repair damaged cable shielding promptly.
- Check couplings, gearboxes and rotary indexing units for mechanical play.
- Do not ignore unusual bearing noise or vibration.
- Protect the motor and encoder against oil, coolant and dust.
- Document the complete servo-drive fault display when positioning deviations occur.
- Check repeatability over several positioning cycles.
- Document all model designations and connection variants before replacing any component.